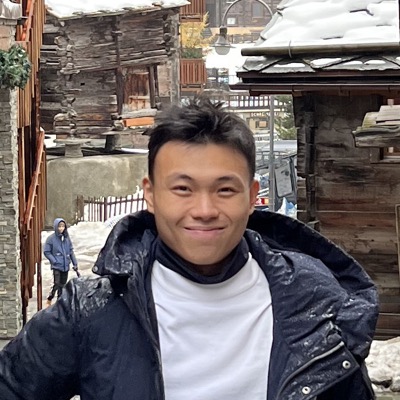
👋🏼 Hi there, I am Zhen Hao!
I am a second-year Robotics PhD student at the University of Michigan, advised by Prof. Bernadette Bucher and part of the amazing Mapping & Motion Lab! My PhD journey is fully funded by the A*STAR National Science Scholarship.
I envision mobile robots that can go anywhere, anytime, autonomously and intelligently, understanding themselves and their environment and using machine learning to keep acquiring and adapting embodied skills. My research interests lie in Embodied Navigation, Interactive Object Search, Physical Intelligence, Skills Acquisition and Adaptation, 3D Path and Motion Planning, and Robot Learning & Foundation Models.
Before my PhD, I was a Robotics Research Engineer at A*STAR, where I had a great time working with Dr. Michael Chuah on legged robots and Physical Intelligence.
Feel free to reach out via email to connect, collaborate, or chat about robots!
🔥 News
- 2026.09: Released PhyGS, a physically grounded scene-generation framework, and ForageBench, a benchmark for interactive object search.
- 2026.05: Excited to join NASA Jet Propulsion Laboratory as a Summer Robotics Intern 2026, working on problems related to embodied AI, robot task learning, and autonomy 🚀
- 2025.09: Featured in A*STAR Graduate Academy’s new series, reflecting on my research path and experience as part of the A*STAR family. Hopefully it inspires the next generation of roboticists! Big shout-out to my mentor, Michael!
- 2025.07: Proud to share the team has been selected for NVIDIA Academic Grant Program on “Adaptive Fault-Tolerant Safe Locomotion with Differentiable Simulation”, led by Prof. Shi Fan (NUS), Dr. Michael Chuah (A*STAR)
- 2025.04: Excited to share that I will be starting my PhD journey this fall in the Robotics Department at UMich under Prof. Bernadette Bucher!
- 2025.03: Proud to announce the team has been awarded the 2024 A*STAR Career Development Fund (CDF) on “Towards Physical Intelligence: Embodiment-Aware Transformer Model for Legged Robots”
- 2024.06: Extremely honoured to be awarded the A*STAR National Science Scholarship PhD!
📝 Publications
PhyGS: Physically-Grounded Controllable Scene Generation
CVPR Workshop on Multi-Agent Embodied Intelligent Systems, 2026
PhyGS generates controllable, photorealistic, and physically interactive building-scale scenes in IsaacSim, with a hardware abstraction for sim-to-real deployment on Boston Dynamics Spot.
ForageBench: A Photorealistic, Physically Grounded Benchmark for Interactive Object Search
2026
ForageBench evaluates interactive object search across 25 house-scale scenes and 100 episodes, combining long-horizon navigation with fine-grained physical interaction.
💼 Experience
NASA Jet Propulsion Laboratory (JPL), Pasadena, California, USA Summer 2026
Summer Robotics Intern, mentored by Erica Tevere and Erik Kramer
- Interaction-aware navigation: using vision and VLMs to identify movable obstacles and regions that may hide traversable space, then verifying movability through physical interaction and proprioceptive feedback to update local navigation maps.
Institute for Infocomm Research (I2R), A*STAR, Singapore Sep 2021 – 2025
Robotics Research Engineer, Embodied Intelligence Task Force, supervised by Dr. Michael Chuah and Dr. Albertus Hendrawan Adiwahono
- Embodiment-aware transformers for legged robots: zero-shot, fault-tolerant locomotion policies that generalize across quadrupeds and humanoids.
- Safe locomotion on unstructured terrain: real-time dynamic probing to estimate terrain collapsibility, and semantic 3D terrain reconstruction for traversability.
- Project Rover-X: GPS goal-driven exploration and traversability analysis for legged robots; delivered a fully autonomous patrolling and people-following demo to HTX and SCDF for HazMat operations, featured in The Straits Times.
🎖 Honors and Awards
- 2025.07: “Adaptive Fault-Tolerant Safe Locomotion with Differentiable Simulation”, NVIDIA Academic Grant Program
- 2025.03: “Towards Physical Intelligence: Embodiment-Aware Transformer Model for Legged Robots”, 2024 A*STAR Career Development Fund (CDF)
- 2024.06: A*STAR National Science Scholarship (NSS-PhD, 5-yr funding for Ph.D. study), Singapore
- 2019.08: Dean’s List, Academic Year 2018/2019 (Top 5% of the Cohort)
- 2019.06: NTU EEE Partial Financial Award for GEM Explorer
- 2018.08: Dean’s List, Academic Year 2017/2018 (Top 5% of the Cohort)
- 2017.07: GCE A-Level High Achiever Award (4A*)
📖 Education

University of Michigan, Ann Arbor, Michigan, USA Aug 2025 – Present
PhD Student, Michigan Robotics Department
Advisor: Prof. Bernadette Bucher
Nanyang Technological University (NTU), Singapore Aug 2017 – Jun 2021
B.Eng (Electrical and Electronic Engineering), Honours (Highest Distinction)
Thesis: Vision-based Robot Navigation via DRL · Advisor: Prof. Xie Lihua

Technical University of Munich (TUM), Munich, Germany Oct 2019 – Mar 2020
Student Leader, Winter Semester Exchange (Fakultät für Elektrotechnik und Informationstechnik)